Projects
|
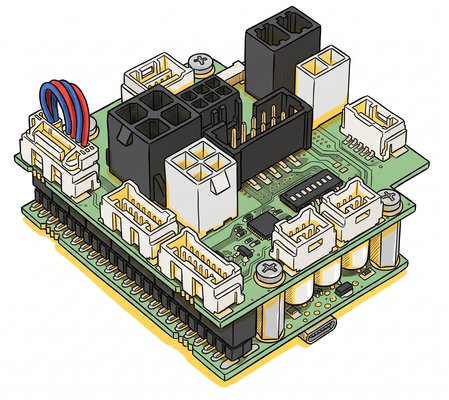
EPOS4/EPOS2 CanOpen Controller CanOpen implementation on an STM32F103 for real-time, low-cost control of single- or multi-motor systems with EPOS4/EPOS2 or any other CanOpen device. |
|
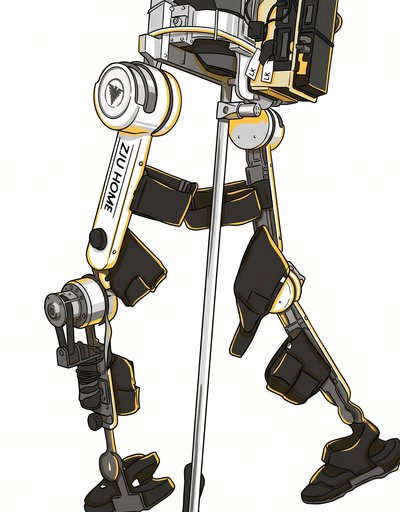
Lower-limb rehabilitation exoskeleton with 6 active DoF at the hip and knee. Built on STM32, EPOS4 and maxon motors, it combines real-time trajectory planning with impedance control for personalised training. |
|
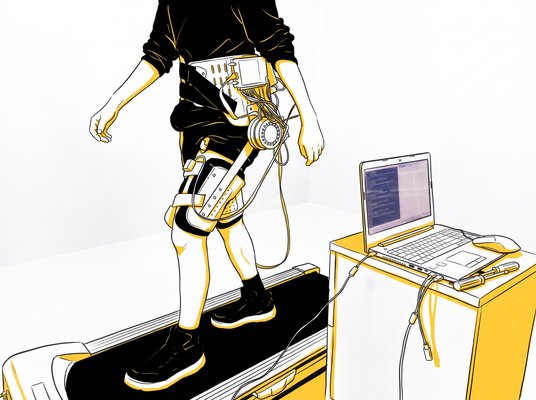
Portable hip exoskeleton that reduces walking effort, assisting hip flexion and extension. It recognises gait phase in real time on varied terrain and tunes assistive torque for each user through human-in-the-loop optimisation. |
|
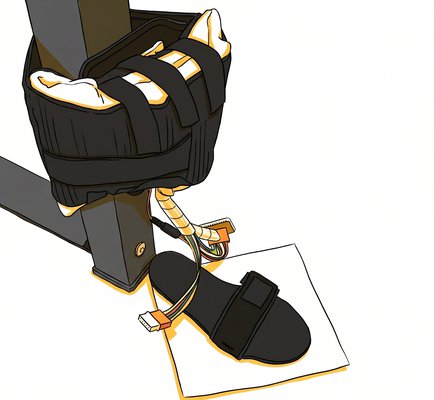
Pathological Gait-Recognition System (PGRS) Low-cost system that monitors children's gait and flags pathological patterns early, before they lead to problems such as osteoarthritis or scoliosis. |